Press Space to continue
This approach solves a critical bottleneck in robotic control by
Press Space to continue
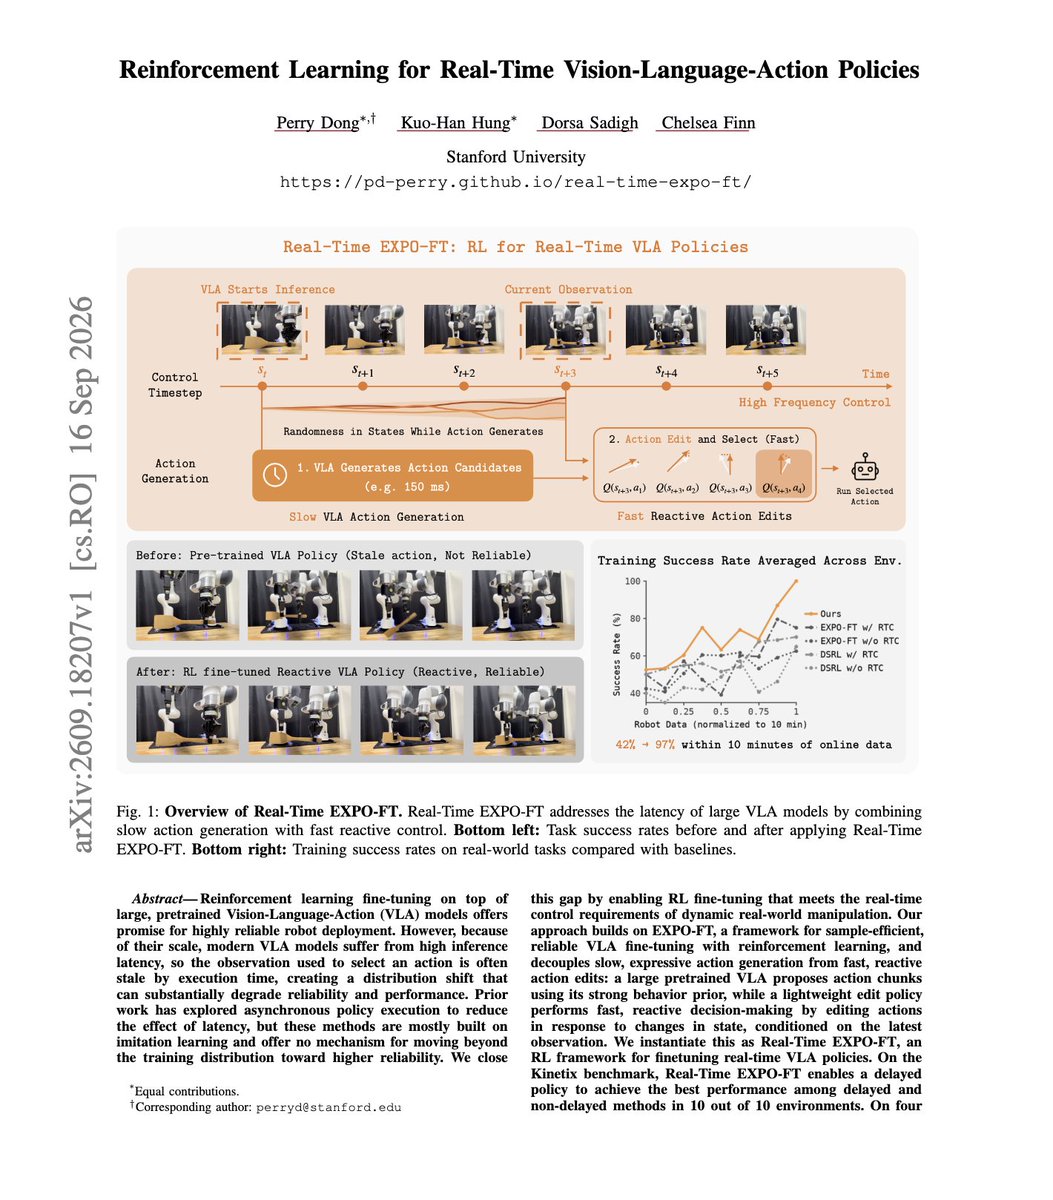
“Reinforcement Learning for Real-Time Vision-Language-Action Policies” VLA models are usually too slow for reactive robot control, so this paper lets the VLA generate actions slowly in the background, while a lightweight RL policy uses the latest observation to rapidly edit and select actions in real time. This simple split improves real-world success from 42% to 97% with just 10 minutes of online robot data. https://alphaxiv.org/abs/2609.18207
open on x · 5 viewsViews and clicks count once per visitor per day. Clicks are opens of this post on X.